5th Workshop on Maritime Computer Vision (MaCVi)

MaCVi @ WACV 2027

Challenges

MaCVi @ WACV 2027 will feature benchmark challenges spanning underwater and surface-based maritime computer vision. Tracks are being added as they're finalized — more datasets, metrics, timelines, and participation rules will be announced soon.

Stay tuned to this page and the MaCVi Discord community for challenge updates.

Challenge Schedule

Provisional: the challenge dates below are our planning schedule and may change as track-specific evaluation timelines are confirmed. The WACV publication deadlines of November 2 and November 20 are fixed.
Event Date
Author details and active OpenReview profiles confirmed October 23, 2026, 23:59 AoE
Final challenge submission deadline October 27, 2026, 23:59 AoE
Final results and winner notification October 30, 2026

All potential challenge-summary coauthors must confirm their publication details and have an active OpenReview profile by October 23, before winners are selected. Completing these details does not guarantee inclusion in the summary paper. Metadata submission instructions will be published separately.

You can begin developing and submitting challenge results before completing author metadata. If you need a new OpenReview account, please start registration by October 9: activation can take up to two weeks.

AoE means Anywhere on Earth (UTC−12). The organizers will hand off the summary paper's final metadata by November 2, 2026. The archival camera-ready deadline is November 20, 2026, 23:59 Pacific Time (PST, UTC−8). See the paper publication schedule for details.

Challenges Overview

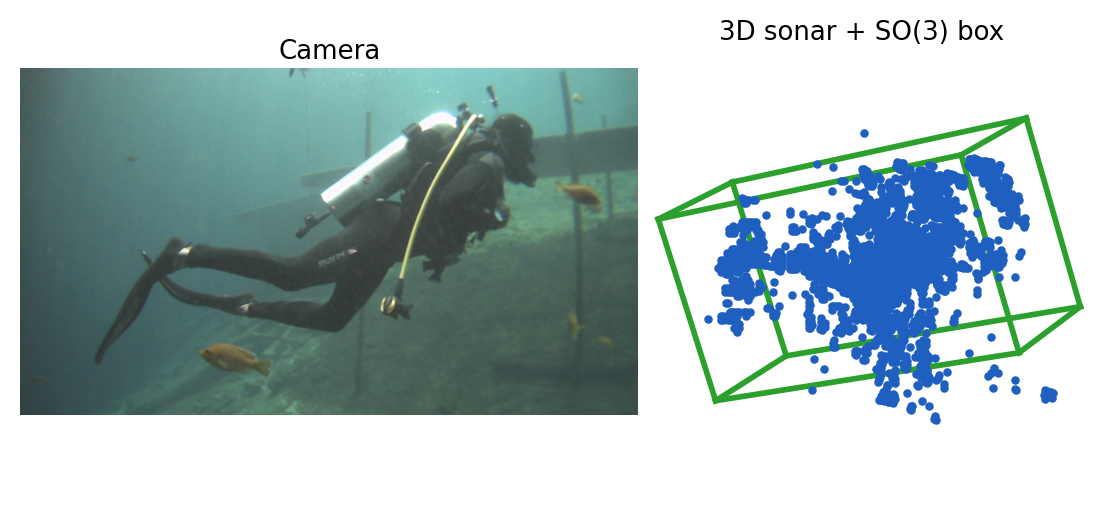
A diver on camera and the same diver as 3D sonar returns with its annotated oriented box.
Camera view and 3D sonar returns of one diver from the Diver3D dataset (CC BY-NC 4.0).

Diver3D: 3D Sonar Diver Detection

Detect divers as full 9-DoF oriented boxes — centre, extents and a complete SO(3) rotation — from sparse 3D sonar point clouds. Divers pitch and roll freely, so yaw-only 3D detectors do not apply; ranking is by the Sonar–Diver Detection Score, which weights full-3D orientation error alongside AP. The dataset is available: 36 scenes, 37,010 sonar frames and 34,568 annotated divers, with the official scorer included. Online submissions are open.

EURS: Embedded Underwater Restoration and Segmentation

Restore degraded underwater images and segment marine life (background/coral/fish/elasmobranch/other). Two tracks are open: a public, self-serve Dev-set leaderboard, and an embedded track scored on real Jetson AGX Orin hardware that carries more weight towards final standings.